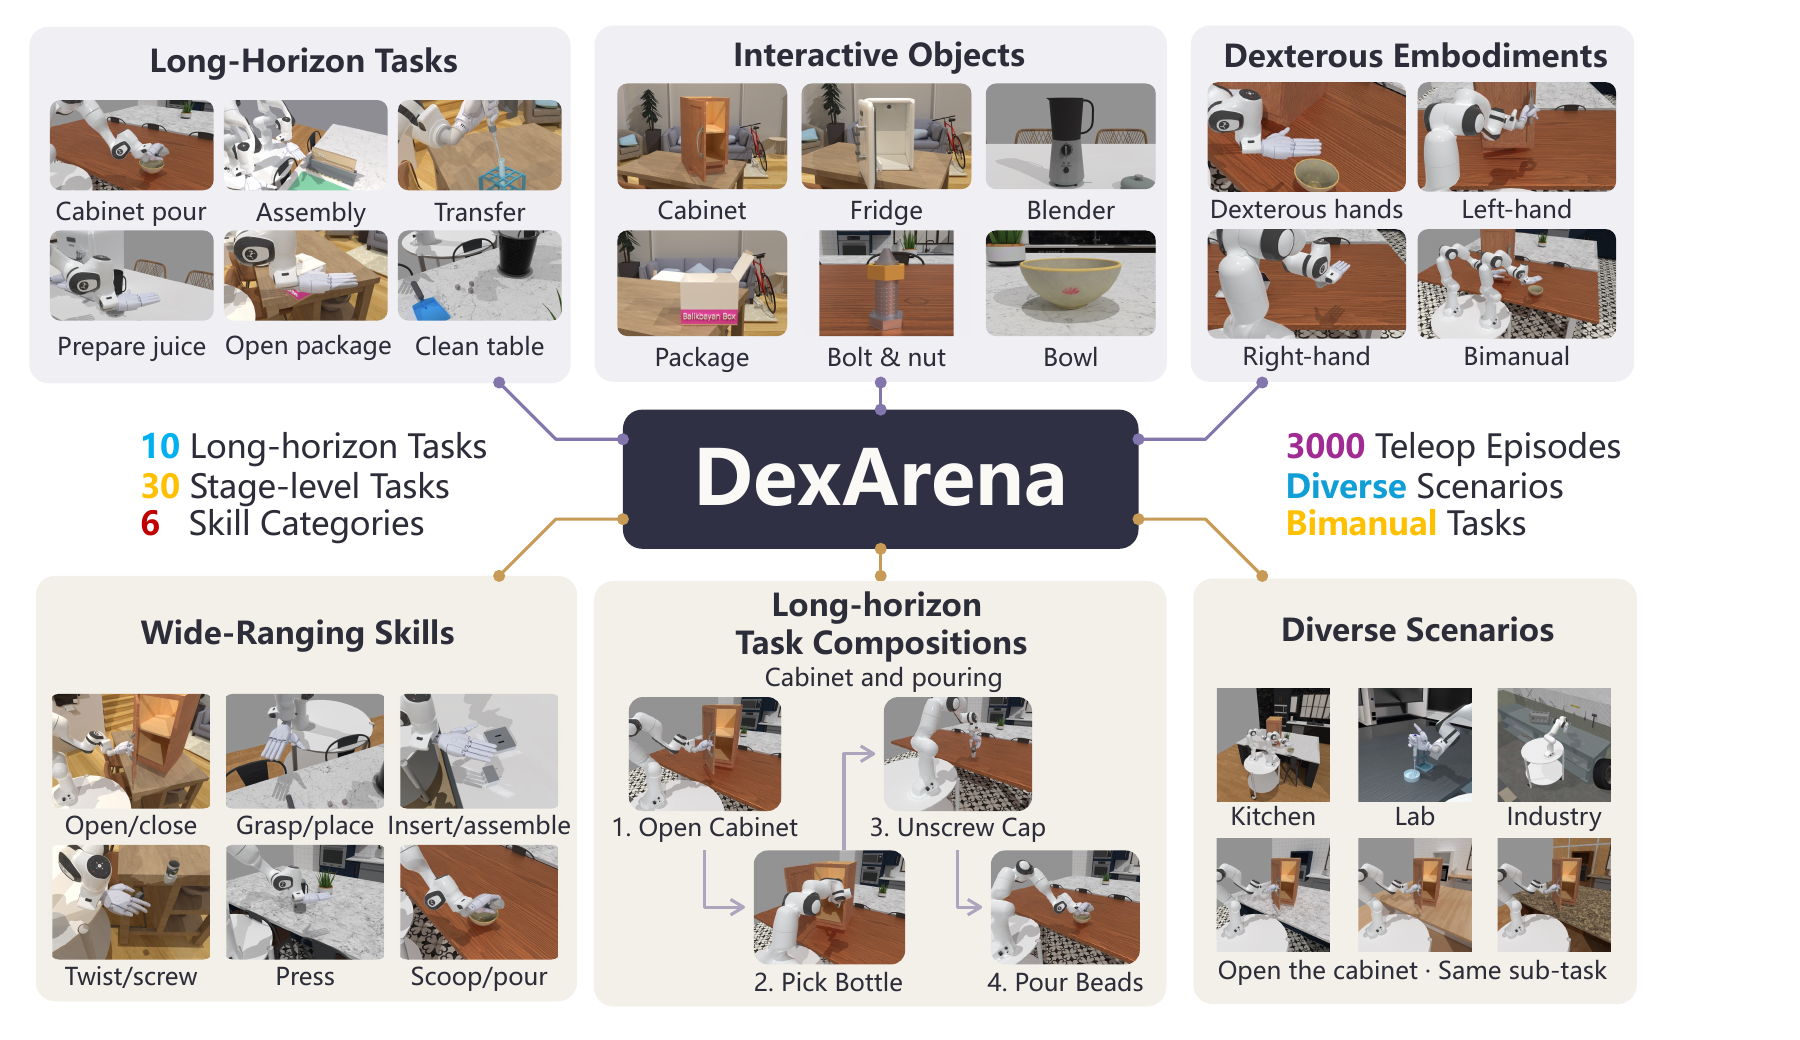
DexArena: A Unified Benchmark for Long-Horizon Dexterous Manipulation
Ten long-horizon tasks and thirty stage environments connect skill execution, visual generalization and bimanual composition through physically grounded success conditions.
Research, institute coverage and conversations shaping embodied intelligence.
The benchmark paper and its accompanying technical notes.
Ten long-horizon tasks and thirty stage environments connect skill execution, visual generalization and bimanual composition through physically grounded success conditions.
A shared factory standardizes robot setup, table placement and policy cameras across the 30 × 3 scene matrix.
One hundred replay-successful episodes per stage retain the simulator state for restoration and offline rendering.
Compare PPO, RLPD, ACT, Diffusion Policy, GR00T and π0.5 on execution, scene transfer and full sequences.
Explore manuscript results →Technical notes describe the current project, not separate publications. Code
Selected institute announcements and independent coverage of PAIR's research conversations.
English editorial summaries link to the original publications. These are institute and conference updates, not independent evaluations of DexArena. Dates below identify coverage, not the conference dates.
A PAIR conference discussion examines AI-assisted calibration and quantum software, alongside the limits of current quantum approaches to learning.
Dapeng Yu's keynote addresses the distance between today's devices and useful large-scale quantum computation, including error correction and system integration.
Weinan E discusses shared scientific infrastructure and the changing relationship between computation, experiments and research organization in his PAIR keynote.
PAIR's inaugural annual conference announcement introduces four tracks connecting intelligent computing, embodied systems, scientific discovery and new computing paradigms.
Conference coverage and the benchmark's publication status, kept clearly separate.
Shanghai, China
The inaugural annual conference brought academic and industry researchers together around four Physical AI tracks. The program combined academic discussions with invitation-only industry sessions.
Submission #13718 · OpenReview
DexArena is an ICLR 2027 conference submission. The public record was modified on 6 October 2026. This is a submission status, not an acceptance or a confirmed presentation.
Independent evaluations should identify the policy, task scope, benchmark revision and protocol, with per-episode evidence and reproducible aggregate results.
No independent studies are listed yet. Public leaderboard submission intake is not open.